
The Cambridge Minicar is a low-cost mobile robot platform with Ackermann steering.
It fits within a 75 x 81 x 197 mm box, weighs 450g (including batteries), costs $76.5 and can be built in 3 hours. The motors can be powered for 2.2 hours when running at 0.3 m/s and the logic can be powered for over 5 hours. The minimum turning radius is 0.56 m, the maximum steering angle is 18 degrees and the maximum steering rate is 0.076 rad/s.
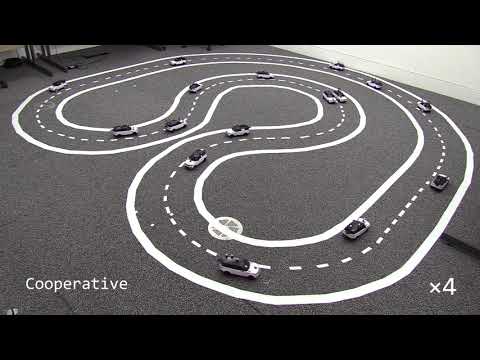
If you use this platform in your research, please cite our paper:
@inproceedings{hyldmar2019fleet,
  title={A fleet of miniature cars for experiments in cooperative driving},
  author={Hyldmar, Nicholas and He, Yijun and Prorok, Amanda},
  booktitle={2019 International Conference on Robotics and Automation (ICRA)},
  pages={3238--3244},
  year={2019},
  organization={IEEE}
}
Dr Amanda Prorok: asp45@cam.ac.uk
Yijun He: yh403@cam.ac.uk
Nicholas Hyldmar: nh490@cam.ac.uk